
AutomotiveProject in focus
One road scene. Connected sensor data.
Turn complex road scenarios into inspectable batches, linking images, point clouds and object identities.
- sequences
- 12
- Synchronized keyframe groups
- 1,200
- Scene types
- 4
Read the project briefAUTO-001
A perception team wants to examine multimodal associations and challenging scenes in one organized batch.
- Project need
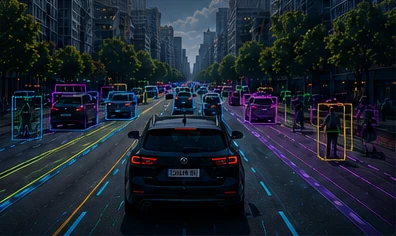
- Organize 12 sequences and 1,200 synchronized keyframe groups. Each group links six images and one point cloud across junctions, night and backlight, roadworks and mixed traffic.
- Key challenge
- Occlusion and low light make boundaries uncertain. The same object across cameras and LiDAR needs consistent identity, timing and coordinate references.
- Approach
- Calibrate rules using edge cases, then review objects, tracks and 2D / 3D links by sequence. Associate issues with scenes and rule versions for revision.
- Handover
- Sequence indexes, frame labels, cross-modal links, calibration references and batch-review records.
 Download project briefs
